
In today's information overload, the biggest challenge is no longer accessing information, but rather absorbing and analyzing it quickly. This is where Google has stepped in brilliantly with NotebookLM, which many describe as a "seco
 |
| Future Tech Car AI Architecture |
For over a century, the automotive industry was a cathedral of mechanical engineering. The value of a vehicle was defined by the roar of its internal combustion engine, the precision of its transmission, and the raw metric of horsepower. However, as we move through 2026, we are witnessing the most significant transformation since the invention

The global automotive landscape is undergoing a monumental shift that eclipses the transition from horse-drawn carriages to the internal combustion engine. We have officially entered the era of the "Mobile Brain." In 2026, a vehicle is no longer evaluated by its mechanical assembly or traditional horsepower. Instead, the modern automobile has transformed into a sophisticated, high-performance computing platform on wheels. This radical evolution is driven by the rapid convergence of next-generation AI automotive technology in 2026, advanced autonomous driving neural networks, and the structural flexibility of software-defined vehicles.
For decades, automotive manufacturing focused on mechanical tolerances, transmission gear ratios, and thermal management of fossil fuel combustion. Today, those engineering challenges have been thoroughly commoditized. The contemporary battlefield of transportation is fought purely in the silicon layer and the cloud infrastructure. The leading automotive pioneers are no longer just heavy-industrial manufacturers; they are artificial intelligence powerhouses deploying multi-modal neural models that process petabytes of environmental data in real time. This comprehensive technical deep dive explores the architectural, economic, and electromechanical transformations redefining global mobility.
The core structural transformation of the modern car lies within its centralized processing architecture. Historically, a conventional vehicle relied on a fragmented network of dozens of isolated Electronic Control Units (ECUs). Each individual ECU was hardcoded to manage a single, specific function—such as controlling anti-lock braking, manipulating power windows, or regulating climate control. This legacy distributed architecture created massive data silos, rendering real-time, vehicle-wide algorithmic synchronization entirely impossible.
In 2026, the paradigm has shifted entirely to centralized high-performance computing chips, exemplified by systems like the NVIDIA DRIVE Thor and proprietary custom application-specific integrated circuits (ASICs). These massive system-on-chip (SoC) architectures act as the centralized "Mobile Brain" of the vehicle, executing hundreds of Tera Operations Per Second (TOPS). By consolidating all computational workloads into a single execution environment, software-defined vehicles can break down data barriers, allowing telemetry from the suspension, electric motors, and surround-vision sensors to fuse instantly into a single operational matrix.
Early iterations of driver-assistance platforms relied heavily on rigid, hand-coded heuristics. Engineers wrote deterministic "if-then" statements to dictate vehicle behavior. For instance, if a radar sensor detected an object within a three-meter radius, the system triggered a linear braking sequence. While functional in highly controlled highway environments, these rule-based frameworks utterly failed when confronted with the chaotic, unpredictable variables of dense urban driving.
Modern autonomous driving neural networks utilize multi-modal Transformer models that closely mimic human visual perception and cognitive understanding. Instead of analyzing the world as isolated geometric obstacles, the vehicle’s vision network performs deep semantic segmentation. It distinguishes between a plastic bag blowing in the wind and a small animal darting off the curb. By processing video streams from ultra-high-resolution CMOS sensors simultaneously, the vehicle constructs a dynamic, four-dimensional vector space of its surroundings, accurately predicting the future trajectories of pedestrians, cyclists, and surrounding traffic units seconds before they occur.
Statistical validation from rigorous real-world telemetry confirms that autonomous systems operating in 2026 reduce vehicular accidents caused by human factors—such as distracted driving, micro-sleep, emotional impairment, and delayed reflexes—by more than 90 percent. Human drivers inherently suffer from cognitive fatigue and sensory limitations; an AI vision system maintains absolute, 360-degree situational awareness indefinitely, filtering out environmental noise and performing optimal path-planning computations within milliseconds.
The primary engineering bottleneck to achieving flawless urban autonomy was never the standard commute; it was the "long tail" of highly improbable edge cases. These represent anomalous scenarios that a driver might encounter only once in a lifetime—such as an unmapped construction detour marked by irregular hand signals from a worker, a flock of birds occupying an intersection during a severe rainstorm, or structural debris falling from a truck ahead.
To overcome these challenges without experiencing system freezes, 2026 autonomous platforms rely on vision-language-action (VLA) foundation models running locally on edge compute hardware. When the vehicle encounters an extreme anomaly that cannot be categorized by its primary operational model, the VLA engine runs rapid probabilistic simulations to determine the path of absolute safety. If the epistemic uncertainty exceeds strict safety boundaries, the vehicle utilizes high-bandwidth, low-latency 5G vehicle-to-everything (V2X) communication to establish a secure link with a remote teleoperation center, allowing a human supervisor to provide high-level directional guidance without needing to physically steer the car.
The practical validation of Level 4 autonomy has catalyzed an aggressive restructuring of transportation microeconomics, driving the rise of the autonomous ride-hailing network, commonly known as the Robotaxi economy. For over a century, private car ownership was viewed as a mandatory cornerstone of personal mobility. Yet, from an objective financial standpoint, a privately owned passenger vehicle is an exceptionally inefficient investment, remaining completely stationary and underutilized in parking structures for approximately 95 percent of its operational life.
By eliminating the single largest operational expense of ride-hailing—the human driver's labor cost, which historically accounted for roughly 60 to 70 percent of a ride's fare—autonomous fleets have effectively driven the per-mile cost of on-demand transportation below the financial threshold of private vehicle maintenance, insurance premiums, depreciation, and urban parking fees. Consumers are rapidly transitioning away from asset ownership toward highly flexible, subscription-based Mobility-as-a-Service (MaaS) frameworks.
As massive fleets of driverless vehicles optimize their deployment patterns based on real-time consumer demand curves, the physical architecture of modern cities is adapting rapidly. Urban real estate formerly consumed by concrete parking garages and multi-lane street parking is being aggressively reclaimed by municipalities. These spaces are being repurposed to expand pedestrian walkways, green parks, and high-density residential housing developments.
Vehicles operating within a centralized Robotaxi network do not need to park in premium downtown areas when demand drops during off-peak hours. Instead, the fleet utilizes predictive demand modeling to autonomously route underutilized units to decentralized, fully automated industrial depots located outside major city perimeters. At these facilities, specialized robotic systems engage in rapid preventative maintenance, interior sanitization, and automated thermal diagnostic evaluations, ensuring each vehicle operates at peak performance before re-entering active service.
The profound computational intelligence of 2026 cannot be isolated from the concurrent clean energy transition. The true masterstroke of modern automotive engineering lies in the deep, algorithmic integration between artificial intelligence and the physics of the electric drivetrain. Advanced software-defined vehicles rely on dedicated neural engines that manage power consumption, inverter switching frequencies, and electric motor efficiency AI protocols with surgical precision.
In high-power industrial and automotive applications—specifically involving three-phase AC squirrel-cage induction motors and permanent magnet synchronous motors (PMSMs)—overall system efficiency is explicitly governed by thermodynamics. When high currents pass through the copper stator windings, significant energy is dissipated as waste heat due to Joule heating, mathematically defined by the expression:
$$P_{loss} = I^2 R$$
Where $I$ represents the stator current and $R$ represents the internal electrical resistance of the copper coils. As temperature increases, the physical resistance of the copper rises proportionally, creating a negative feedback loop that degrades motor efficiency and threatens to compromise the structural integrity of the winding insulation material.
To mitigate these thermodynamic losses, the vehicle's onboard neural engine runs real-time predictive thermal models that continuously monitor current loads, rotor velocity, and heat dissipation behavior across the stator core. Instead of relying purely on reactive liquid-cooling loops, the AI proactively modifies the pulse-width modulation (PWM) switching frequencies of the silicon carbide (SiC) inverters. If the predictive algorithm forecasts a localized thermal spike in the copper coils during an extended high-torque demand scenario, it dynamically re-optimizes the electromagnetic field distribution within the stator slots, minimizing current density bottlenecks before physical overheating occurs.
Furthermore, this meticulous level of algorithmic control extends directly to regenerative braking systems. Traditional regenerative braking architectures utilize static, pre-programmed deceleration curves that fail to account for dynamic variables such as changing road surface friction coefficients, instantaneous tire slip ratios, or the precise chemical state-of-charge (SoC) of the battery cells. In 2026, machine learning algorithms continuously aggregate input data from electronic stability control modules and predictive computer vision backbones to calculate the absolute mathematical maximum of kinetic energy that can be inverted back into the high-voltage battery pack without compromising vehicle stability or causing overcurrent cell degradation.

The rapid momentum of this technological evolution has radically disrupted the global financial landscape. Wall Street and international venture capital firms have completely abandoned legacy metrics of automotive valuation, such as raw vehicle production volumes or quarterly unit deliveries. The modern "investment compass" points directly toward companies that command proprietary positions within three foundational pillars of the autonomous ecosystem:
The primary value capture in the modern automotive supply chain has shifted entirely from chassis fabricators to semiconductor design firms. Capital is flowing aggressively into specialized silicon providers capable of engineering ultra-low-power, high-TOPS neural processing architectures. A company that controls the computational hardware capable of running massive autonomous driving neural networks under constrained thermal and electrical boundaries holds an incredibly lucrative, highly defensible monopoly in the global industrial market.
The monetization of transportation has transitioned firmly to a recurring revenue model. High-margin software stacks that drive full autonomy are licensed as ongoing subscriptions to logistics corporations, public transit authorities, and commercial delivery fleets. The immense cost of gathering billions of miles of real-world driving telemetry and training multi-billion parameter foundational vision models ensures that only a tiny handful of elite tech firms can deliver verifiably safe autonomous software, creating an absolute economic moat around their proprietary platforms.
With millions of highly intelligent, software-defined electric vehicles moving through the built environment, managing aggregate energy distribution has emerged as a massive financial frontier. Modern investment strategies prioritize the development of automated Vehicle-to-Grid (V2G) orchestration frameworks. When connected to the smart grid, parked autonomous fleets act collectively as an immense, distributed energy storage system. Driven by predictive AI pricing models, these vehicles absorb excess renewable energy during peak solar and wind production windows and discharge power back into municipal grids during high-demand evening hours, transforming the automobile into an active participant in global macroeconomic stability.
The profound transformation witnessed in 2026 confirms that the automobile has evolved far beyond its identity as a passive mechanical tool. It has successfully become an interactive intelligence partner. The traditional boundaries that once separated consumer electronics, artificial intelligence, heavy industrial manufacturing, and municipal energy infrastructure have completely dissolved. The global race is no longer centered on who can assemble the fastest or most visually striking vehicle, but on who can develop, scale, and secure the safest, most efficient algorithmic mind to guide it. In this new era, we are no longer driving the future; the future is actively driving us forward into an autonomous, electrified reality.
The Neural Engine: How AI and NVIDIA Drive Thor Are Redefining Vehicle Architecture
The End of Driving: How Generative AI is Creating 'Thinking Cars' in 2026
Enhance your driving safety and secure absolute proof on every journey with the ultimate smart co-pilot. The REDTIGER F7NP features stunning 4K front-facing and 1080P rear video quality to capture the finest roadside details.
Ideal for daily commutes, long road trips, and active continuous surveillance loops.
Stay updated with the latest tech insights and automotive innovations. Follow my official profiles across these platforms to connect directly:
🔄 Article Update (July 2026): This technical guide has been updated with detailed core diagnostics telemetry, high-resolution sensor fusion workflow diagrams, and structural compute layout schematics.
The era of the "mechanical-only" car is dead. In 2026, a vehicle is no longer just a chassis, a collection of stamped sheet metal, and an internal combustion or basic electric engine; it is a highly integrated mobile data center. As Artificial Intelligence (AI) migrates rapidly from our smartphones and cloud servers directly into our physical drivetrains, the traditional boundary separating hardware from software has entirely vanished. Here is how AI is fundamentally rewriting the DNA of modern automotive engineering through the deployment of an AI-powered vehicle architecture
Historically, automotive design relied heavily on distributed electronic control units (ECUs), where a single premium car could contain upwards of a hundred localized computers, each running isolated software loops for specific tasks like power windows, braking, or cabin climate control. This legacy approach is fundamentally incompatible with the fast-paced evolution demanded by generative AI, neural networks, and massive computational pipelines. The paradigm shift of 2026 replaces this fragmented approach with a centralized, unified, and highly adaptive electronic nervous system. This transition represents a monumental structural shift towards an integrated AI-powered vehicle architecture that treats the vehicle as a single, holistic computational node capable of continuous learning and adaptation
This deep-dive technical article explores how this architectural transformation impacts every layer of contemporary vehicle engineering. We will examine the transition from simple mechanical wear monitoring to advanced predictive machine learning intelligence, delve into the physics of electric motor core diagnostics via neural telemetry, explore how sensor fusion allows computers to see the invisible road, and analyze the macroeconomic and technical battlegrounds where American and Chinese manufacturers are fighting for autonomous structural superiority
The traditional automotive maintenance model has always been reactive or, at best, strictly schedule-based. Drivers changed fluids, inspected brakes, or replaced belts based on elapsed mileage or after an audible component failure occurred. In the context of next-generation electric vehicles (EVs), this method is dangerously inefficient and costly. Today, sophisticated machine learning models integrated into the core of the AI-powered vehicle architecture shift this dynamic entirely from retrospective tracking to real-time, proactive foresight

Figure 1: Complete pipeline of real-time multi-sensor telemetry and hybrid fault diagnostics inside the EV powertrain architecture
The exclusive edge of this technological wave lies in longevity and reliability. While the vast majority of consumer-facing automotive blogs focus almost entirely on the flashier aspects of full self-driving (FSD) beta software and highway lane-merging maneuvers, technical engineers are focused on operational lifespan and structural asset protection. AI is now deeply integrated into the internal motor winding sensors and specialized transformer units of premium electric vehicles. Instead of waiting for an irreversible dielectric or insulation breakdown to trigger a catastrophic component failure, specialized machine learning frameworks—known colloquially as "Neural Diagnostics"—monitor subtle heat signatures, transient thermal anomalies, and high-frequency electromagnetic fluctuations in real-time
The Real-Time AI Impact: Advanced deep learning anomalies algorithms can predict an impending copper coil insulation failure or a micro-leak within the liquid stator cooling loops up to 48 hours before any physical symptoms manifest. This early detection saves fleet operators and individual vehicle owners thousands of dollars in major mechanical overهاuls and completely prevents dangerous on-road thermal runaways
To understand the profound mathematical shift behind this capability, we must evaluate how these systems process live operational telemetry. In a legacy vehicle, thermal monitoring was restricted to a basic thermocouple sending a generic temperature reading to the dashboard. If the motor got too hot, a warning light illuminated. By contrast, a contemporary AI-powered vehicle architecture continuously streams high-fidelity phase-current data, vibrational frequencies, and multi-point thermal variations into a localized neural model. This model cross-references live data against baseline physics profiles to distinguish between standard operational stress and microscopic deviations that indicate real mechanical decay
To appreciate how deeply the neural engine penetrates modern hardware, one must look closely at the stator and rotor configurations inside high-performance induction and permanent magnet synchronous motors. Specifically, squirrel-cage rotors and complex stator copper windings are subject to intense electromagnetic, thermal, and mechanical stresses. Over time, these cyclical stresses lead to micro-fissures in the insulation varnish protecting the individual conductor strands
When an insulation fault begins, it alters the local magnetic flux distribution around the affected slots. Integrated into the AI-powered vehicle architecture are highly sensitive magnetic flux leakage sensors and phase-current monitoring loops. These loops continuously log the symmetrical components of the stator current. By applying a real-time Fast Fourier Transform (FFT) combined with a convolutional neural network (CNN), the vehicle's onboard computer analyzes the harmonic distortion components of the electrical current. The neural framework evaluates specific fault-indicative frequencies, defined mathematically as
Where fs represents the supply frequency, R is the number of rotor slots, s is the motor slip, p represents the number of pole pairs, and n indicates the harmonic order. By recognizing minute changes in these specific spectral sidebands, the onboard Neural Diagnostics suite pinpoints the precise location of a degrading winding turn before an internal short-circuit occurs. This level of granular visibility ensures that maintenance is converted from an emergency breakdown scenario into a highly controlled, predictable, and modular component service
| Diagnostic Dimension | Legacy Sensor Paradigm (Pre-2024) | AI-Powered Architecture Paradigm (2026) | Primary System Benefit |
|---|---|---|---|
| Stator Winding Monitoring | Static thermocouple over-temperature alerts | Real-time CNN-based phase current harmonic analysis | Prevents catastrophic short-circuits via 48-hour advanced warning |
| Rotor Core Inspection | Post-failure physical teardown and visual checks | Electromagnetic flux symmetry neural evaluation | Eliminates structural breakdown risks in squirrel-cage assemblies |
| Cooling Loop Integrity | Fluid level pressure sensors and drop thresholds | Predictive thermal transient pattern matching | Identifies micro-leaks prior to electronic fluid contamination |
Beyond the internal electrical powertrain, the external sensory apparatus of modern vehicles has undergone an equally radical computational rebirth. Modern computer vision sub-systems do not simply "see" the car directly in front of them or track painted highway lane dividers; they calculate deep probabilistic states of the entire surrounding environment. Through the sophisticated deployment of Sensor Fusion—a structural technique that mathematically fuses disparate data streams from ultra-high-resolution cameras, solid-state Lidar modules, and high-frequency digital Radar arrays—the 2026 AI-powered vehicle architecture creates a dynamic, 360-degree real-time volumetric occupancy grid
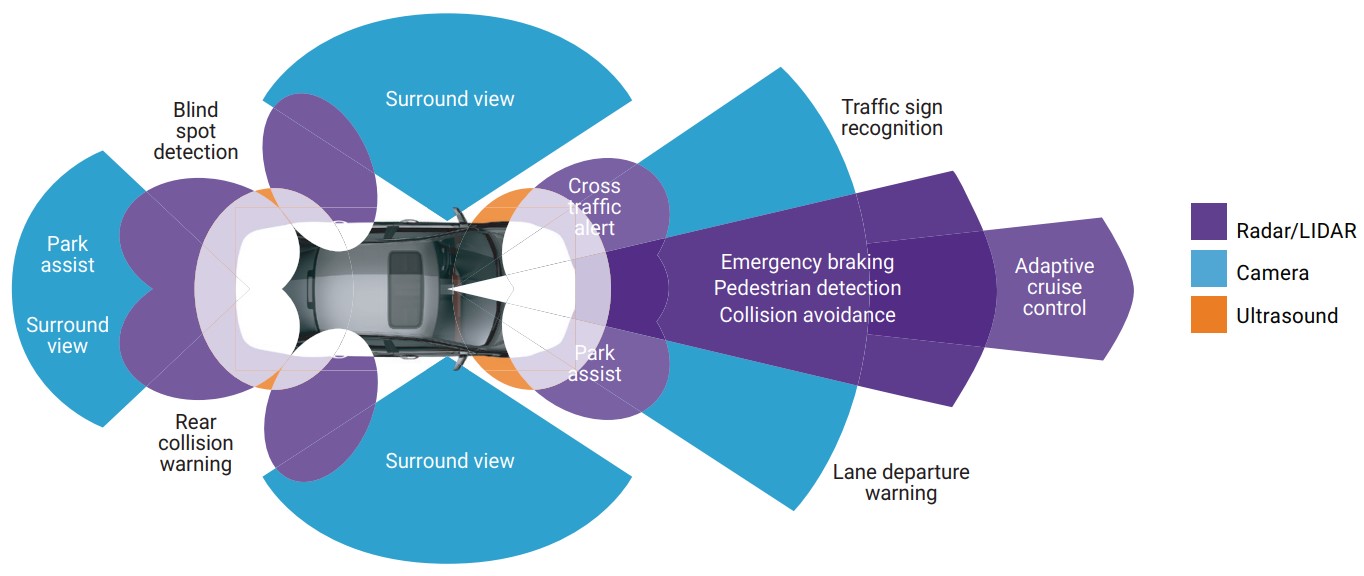
Multi-sensor fusion layout displaying overlapping detection sectors for Cameras, Radar/LiDAR, and Ultrasound sensors
This complex occupancy grid functions as a digital twin of the physical world. Instead of processing individual pixels as isolated fragments, the vehicle’s central transformer models interpret the visual scene holistically. For instance, if a pedestrian is obscured behind a parked delivery van, a legacy vision system would fail to register their presence until they stepped directly into the vehicle's driving path. A modern system, however, tracks contextual clues: the shadows cast underneath the van, the behavioral patterns of surrounding traffic, and historical spatial data from the immediate urban environment. By running millions of forward-looking simulations per millisecond, the neural engine predicts the probability of a pedestrian emerging onto the asphalt, preemptively adjusting the braking pressure and torque vectoring before the hazard is even visible to the human eye
Through this integration, sensor fusion models are now resilient against extreme weather degradations. Heavy rain, dense fog, and blinding sun glare traditionally crippled early automated driving assistance systems. In 2026, if a high-definition camera is temporarily blinded by oncoming high-beam headlights, the AI-powered vehicle architecture seamlessly shifts the primary mathematical weights of its spatial perception layers to the digital radar and solid-state Lidar arrays. This dynamic cross-validation ensures that the vehicle's underlying predictive path-planning algorithm always receives an uncompromised, structurally verified stream of spatial awareness data, maintaining absolute navigational safety under all operational constraints
The practical implementation of these highly demanding machine learning models requires an absolute rejection of traditional automotive electronics computing frameworks. In the past, auto manufacturers added functionality by simply adding more independent chips from various Tier-1 suppliers. This created a chaotic, uncoordinated network that suffered from immense transmission latency, massive wiring harness weight, and severe software update bottlenecks. The modern solution is a highly optimized, centralized computing platform that forms the foundational bedrock of any advanced AI-powered vehicle architecture

Core processing architecture combining discrete CPU, GPU, and NPU computing clusters to execute massive automotive AI workloads
By migrating computational power away from the edges of the vehicle into a central "supercomputing core," manufacturers have achieved a massive consolidation of hardware. This core is typically powered by multi-chip monolithic processors running heterogeneous compute environments—combining massive graphic processing clusters (GPUs) for vision models, dedicated neural processing units (NPUs) for deep learning acceleration, and ultra-secure, lock-step CPU cores for critical safety-actuation systems. This centralized layout allows data to flow instantaneously across a unified high-speed automotive Ethernet backbone, bypassing the slow data transfer constraints of older Controller Area Network (CAN) and Local Interconnect Network (LIN) standards
Furthermore, this architectural consolidation significantly reduces the physical weight and complexity of the vehicle’s internal wiring harnesses. By organizing the physical connections into localized, dumb "zonal gateways" that act purely as data-concentration points and power-distribution hubs, engineers can eliminate kilometers of redundant copper wiring. The data is aggregated at these local zones and blasted directly to the central neural engine via fiber-optic or high-bandwidth twisted-pair cabling. This structural layout not only improves production efficiency on assembly lines but also drastically boosts overall vehicleenergy efficiency, extending battery range and lowering production costs simultaneously
The Ultimate Guide to Software-Defined Vehicles Architecture
Enhance your driving safety and secure absolute proof on every journey with the ultimate smart co-pilot. The REDTIGER F7NP features stunning 4K front-facing and 1080P rear video quality to capture the finest roadside details.
Ideal for daily commutes, long road trips, and active continuous surveillance loops.
Stay updated with the latest tech insights and automotive innovations. Follow my official profiles across these platforms to connect directly:
